Human egocentric data
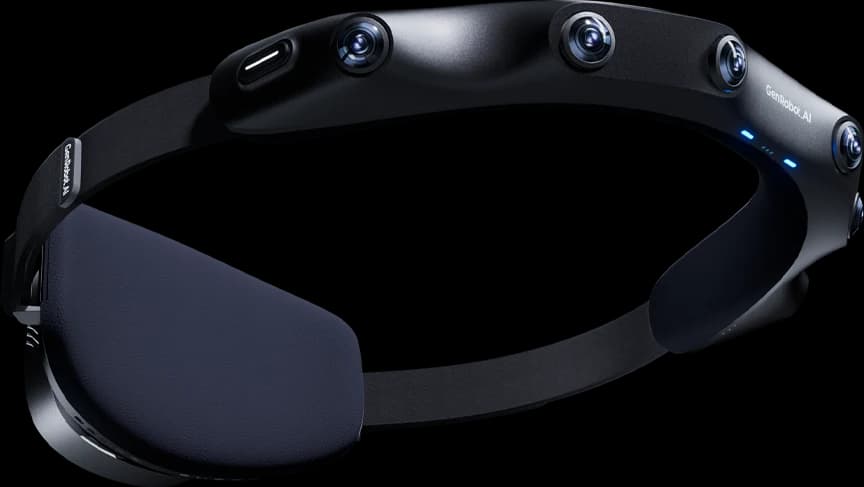
First-person demonstrations of real work, organized into tasks, steps and actions. Build a richer understanding of how people interact with objects and environments.
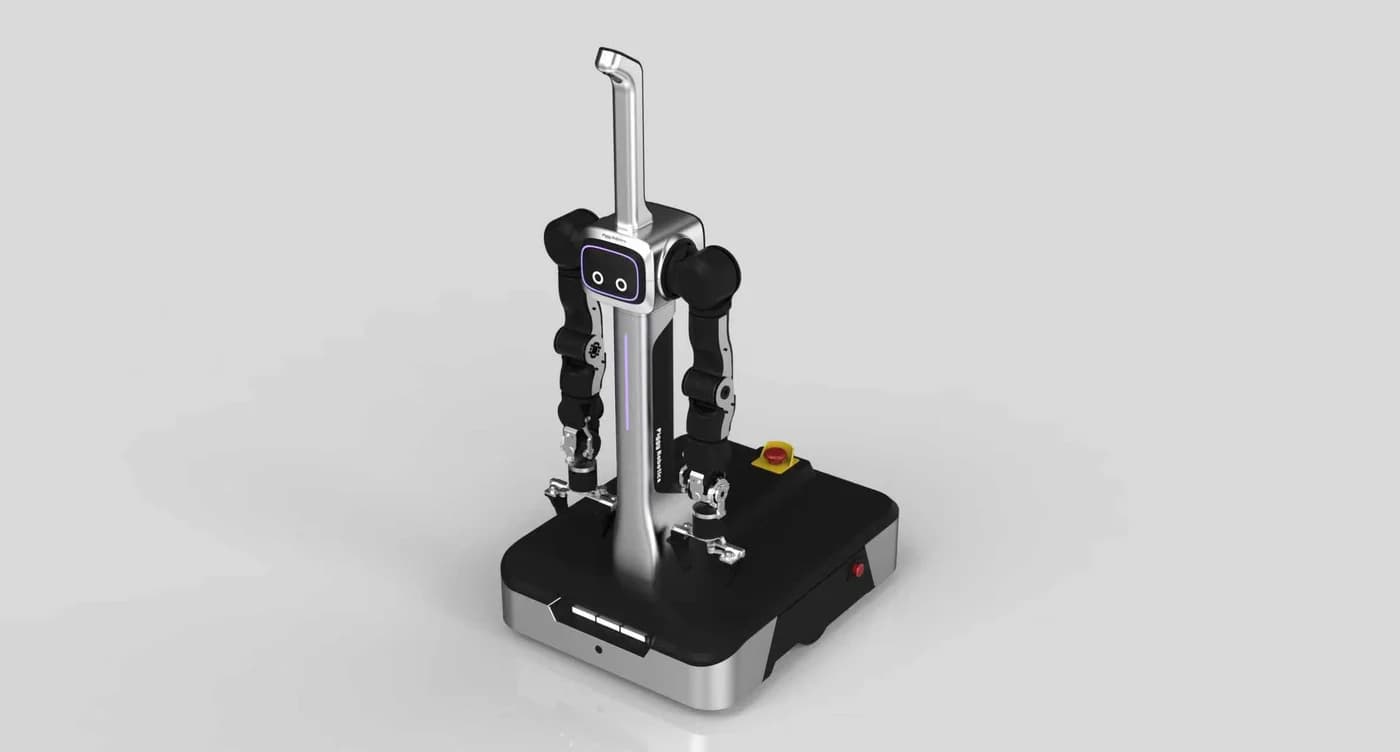
Reference image. Exact equipment and configuration are confirmed per project. Image credits ↗
On-robot task episodes with platform configuration and available observations, states and actions. Align the recording schema with the policy you are training.
Scoped to your project · Request a quotation
No purchase commitment. Availability, scope, lead time and commercial terms are confirmed after requirements review.
| Platforms | Mobile manipulators, dual-arm rigs and humanoids, subject to access |
|---|---|
| Task examples | Pick-and-place, restocking, sorting and tool interactions |
| Signals | RGB / depth, joint state, action and pose where supported |
| Schema | LeRobot, RLDS or a customer schema following compatibility review |
| Control mode | Teleoperation or other agreed collection mode |
| Acceptance | Define task success, invalid episodes and retained failures upfront |
First-person demonstrations of real work, organized into tasks, steps and actions. Build a richer understanding of how people interact with objects and environments.
Commission a task distribution around the objects, settings and failure cases your model needs. Start with a pilot, then scale accepted data against a shared protocol.