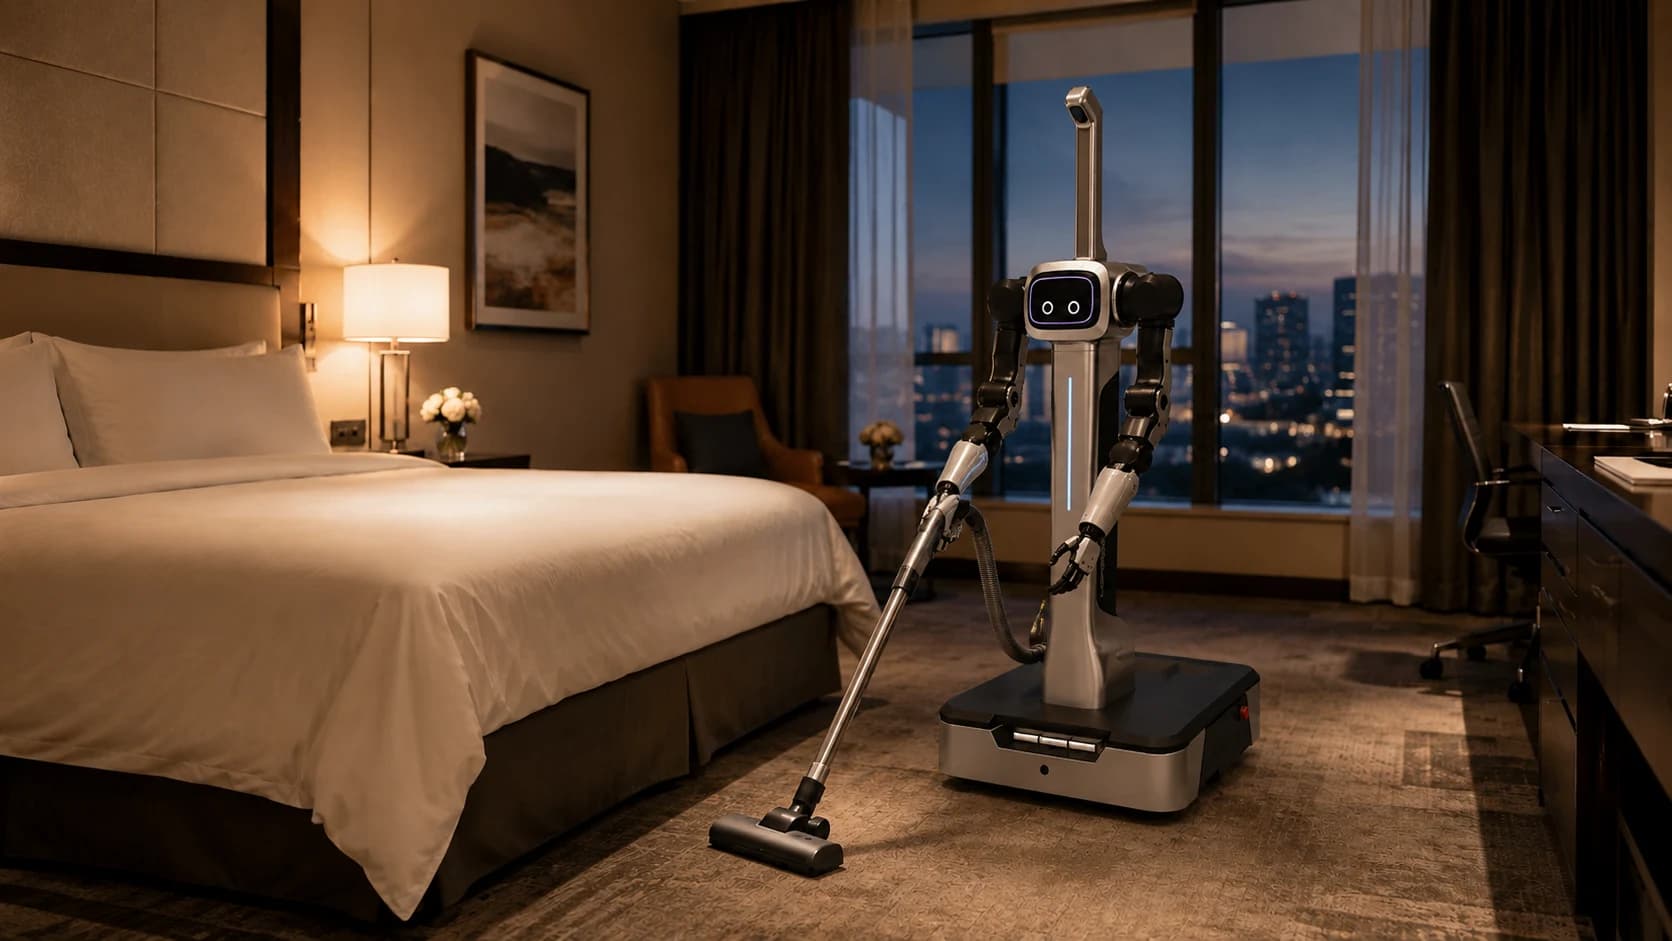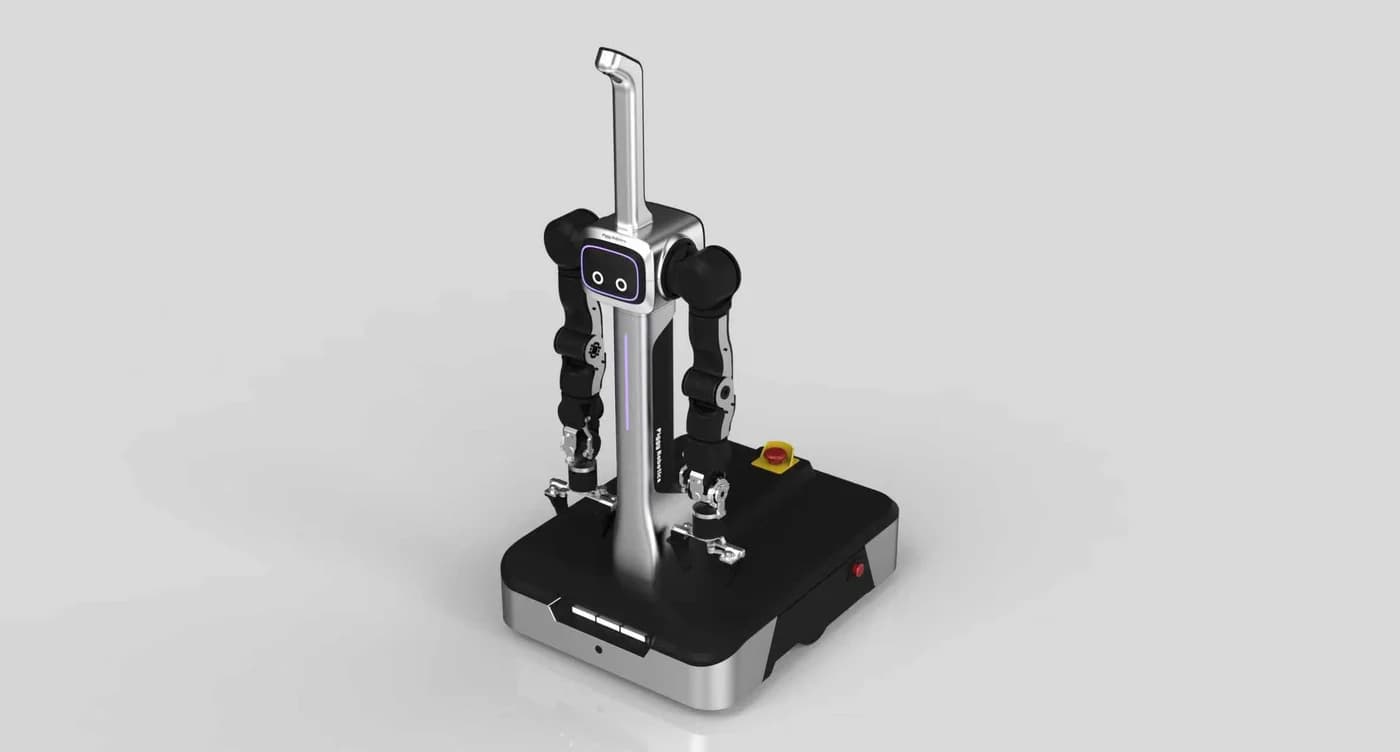
Robot manipulation data
On-robot task episodes with platform configuration and available observations, states and actions. Align the recording schema with the policy you are training.
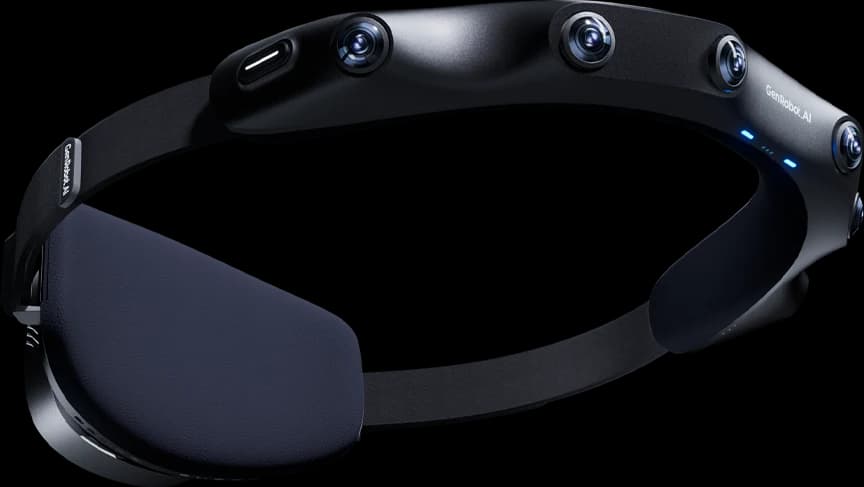
Reference image. Exact equipment and configuration are confirmed per project. Image credits ↗
First-person demonstrations of real work, organized into tasks, steps and actions. Build a richer understanding of how people interact with objects and environments.
Scoped to your project · Request a quotation
No purchase commitment. Availability, scope, lead time and commercial terms are confirmed after requirements review.
| Capture options | Stereo or multi-camera wearable configurations |
|---|---|
| Task domains | Hospitality, housekeeping, object handling and sports operations |
| Annotation | Task / step / action boundaries; object and outcome descriptions |
| Formats | Video plus JSON or Parquet metadata, agreed at sample stage |
| Volume | Quoted in accepted episodes or usable hours |
| Important distinction | Human demonstrations do not inherently contain robot action labels |
On-robot task episodes with platform configuration and available observations, states and actions. Align the recording schema with the policy you are training.
Commission a task distribution around the objects, settings and failure cases your model needs. Start with a pilot, then scale accepted data against a shared protocol.